IN-HOUSE ROBOTICS R&D
Engineered by Shining Robotics.
Mechanical, electrical and embedded development, motion control and in-house SLAM, localization, navigation, path planning and obstacle avoidance.
Explore our R&D capabilities ↗SR-C400 / DIFFERENTIAL-DRIVE PLATFORM
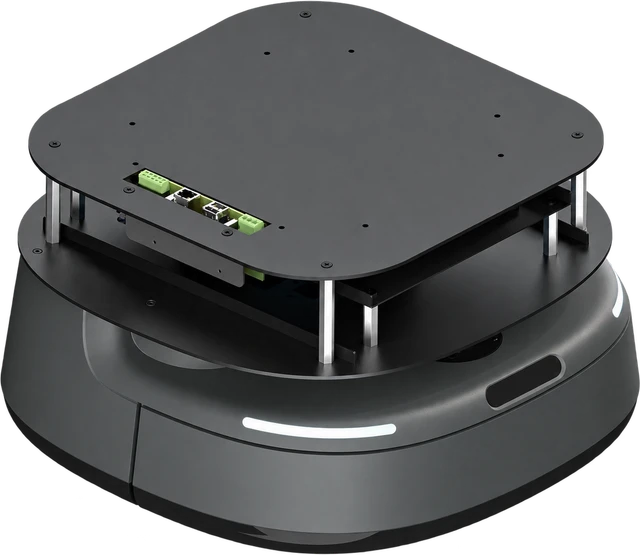
A mobile foundation for developing home robots for companionship, interaction and lightweight item delivery.
IN-HOUSE ROBOTICS R&D
Mechanical, electrical and embedded development, motion control and in-house SLAM, localization, navigation, path planning and obstacle avoidance.
Explore our R&D capabilities ↗SHINING GROUP MANUFACTURING
Established in 1995, Shining Group brings machining, sourcing, assembly, testing and quality management resources to prototype builds and production.
Explore our manufacturing foundation ↗PRODUCT FACTS
| Dimensions (L × W × H) | 400 × 400 × 260 mm |
|---|---|
| Platform weight | 30 kg |
| Maximum payload | 20 kg |
| Maximum navigation speed | 0.5 m/s |
| Battery (voltage / capacity) | 24 V / 10 Ah |
| Navigation | LiDAR-SLAM |
| Navigation sensors | ToF LiDAR × 1 / RGBD × 1 / IMU × 1 |
| Network interface | RJ45 (communication / routing) |
| Mechanical interface | Structural mounting holes |
| Controls and expansion | System switch, emergency stop, USB expansion |
| ROS version | ROS 1 / ROS 2 |
All SR-C and SR-X700 chassis support ROS 1 and ROS 2. Confirm your ROS distribution, operating system, driver package, message definitions, control and feedback interfaces, and software delivery scope for the selected configuration.
INTEGRATION & CONFIGURATION
Structural mounting holes support upper-module integration. Confirm mounting drawings, load distribution and center of gravity.
ROS 1 and ROS 2 support provides a basis for integration. Agree drivers, control commands, status feedback and navigation configuration.
Confirm the hardware, accessories, software, documentation and technical support included in the quotation.
YOUR NEXT STEP
Share the task, operating environment, payload, upper-module dimensions, ROS environment and expected quantity.